
 Kontakt
 Jak kupować

Dostawa
Doradca ds. zakupów
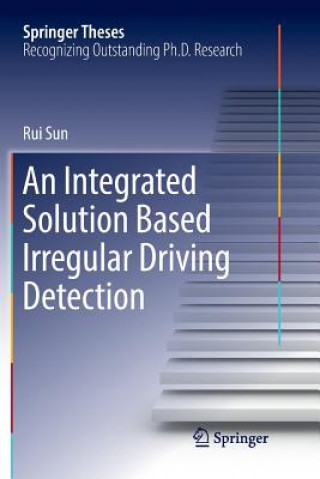
Integrated Solution Based Irregular Driving Detection
 Angielski
 274 b
Nawet do 30 dni na zwrot
Klienci kupili także
 /
 Miękka
 83.55
zł


 /
Twarda
27.16
zł
 /
Miękka
79.75
zł

 /
Miękka
372.25
zł

 /
Miękka
181.76
zł

This thesis introduces a new integrated algorithm for the detection of lane-level irregular driving. To date, there has been very little improvement in the ability to detect lane level irregular driving styles, mainly due to a lack of high performance positioning techniques and suitable driving pattern recognition algorithms. The algorithm combines data from the Global Positioning System (GPS), Inertial Measurement Unit (IMU) and lane information using advanced filtering methods. The vehicle state within a lane is estimated using a Particle Filter (PF) and an Extended Kalman Filter (EKF). The state information is then used within a novel Fuzzy Inference System (FIS) based algorithm to detect different types of irregular driving. Simulation and field trial results are used to demonstrate the accuracy and reliability of the proposed irregular driving detection method.


Informacje o książce
Angielski
Kategoria

Podaruj tę książkę jeszcze dziś
To łatwe
1 Dodaj książkę do koszyka i wybierz „dostarczyć jako prezent” 2 W odpowiedzi wyślemy Ci bon 3 Książka dotrze na adres obdarowanegoMogłoby Cię także zainteresować








Cześć! Jestem Libroamiko, Twój doradca książkowy.
Jak mogę Ci pomóc?